在上面的运动学模型中,我们得到了:
⎩⎨⎧X˙=Vcos(β+δ)Y˙=Vsin(β+δ)ψ˙=Lf+LrVcosβ(tanθ1−tanθ2)(1)
选取状态量为: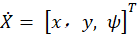 ,控制量
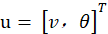 ,对于参考轨迹上的任意参考点用r表示,即:
X˙=f(x,u)⇒rX˙r=f(xr,ur)(2)
其中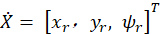 经过泰勒级数展开,并忽略高阶项:
χ˙=f(χr,ur)+∂χ∂f(χ,u)(χ−χr)+∂u∂f(χ,u)(u−ur)(3)
对 和
 求雅可比矩阵,有:
∂x∂f(x,u)=∂x∂f1∂x∂f2∂x∂f3∂y∂f1∂y∂f2∂y∂f3∂ψ∂f1∂ψ∂f2∂ψ∂f3=000000−vrsin(δr+β)vrcos(δr+β)0∂u∂f(x,u)=∂v∂f1∂v∂f2∂v∂f3∂θ∂f1∂θ∂f2∂θ∂f3=cos(δr+β)sin(δr+β)Ltanθ1−tanθ200Lcos2δrvr(4)
则,状态误差的变化量
x˙=x˙−x˙ry˙−yrψ˙−ψ˙r=000000−vrssin(δr+β)vrcos(δr+β)0x−xry−yrψ−ψr+cos(δr+β)sin(δr+β)Ltanθ1−tanθ200Lcos2δrvr[v−vrθ−θr]u~(k)=A~x~(k)+B~u~(k)(5)
接下来进行线性离散化,
x~˙(k+1)=(TA~+I)x~(k)+TB~u~(k)(6)
x~(k+1)=100010−TvrsinψrTvrcosψr1x~(k)+TcosψrTsinψrLT(tanθ1−tanθ2)00Lcos2δrvrTu~(k)=A~x~(k)+B~u~(k)(7)
其中,T为采样步长,I为单位矩阵,维度与A同。
本篇文章受 CC BY-NC-SA 4.0 协议保护,转载请注明出处。